Total Pageviews

Tuesday, July 9, 2013

Launch GNOME session from terminal


  • Switch to a second terminal by pressing: ctrl + alt + F2, and provide an current machine login information
  • start a new X-session: 
$xinit -- :1
  • ssh to target machine with -X option
$ssh -X username@targetmachineIP
  • once logged in, start a new gnome-session
$gnome-session

If you want to switch back to your current machine, just press: ctrl + alt +F7

Friday, June 28, 2013

Joystick on Groovy

Get a package from aptitude

sudo apt-get install ros-groovy-joystick-drivers

Follow this tutorial, start from topic "1.2 Configure the Joystick" onward, to configure a permission.

To start using the node, just run

rosrun joy joy_node

When node is running, you should be able to see topic named "/joy". To see data flow, just run

rostopic echo /joy

Tested using Xbox360 joystick for Window, on Ubuntu 12.04 running ROS Groovy.

Wednesday, March 6, 2013

Backup script


To make life a bit easier a backup script is attached here (at the end of this page) to make a full-system backup. The script will do the following:

  • It will empty your trash.
  • make an list of files and folder that to don't want to backup (an exclude_file mentioned as above). Files ended with .bag, .mpg, .mpeg, .avi, .png will be exclude and also everything in /tmp and /download folder.
  • then it will create a destination folder at your argument directory.

Usage of the script

chmod +x fullbackup.sh 

and then (assumed that you want to put a backup file at /home/golfcar)

./fullbackup /home/golfcar  

After backup finish, you will see a folder named like golfcart-master-010313.tgz where "golfcart-master" is your hostname and "010313" is a backup date (01/03/2013).

The script can be download from here

 link

Reference:
https://help.ubuntu.com/community/BackupYourSystem/TAR
https://sites.google.com/site/fmautonomy/private/documentation/backups

Thursday, December 13, 2012

DBSCAN

I was looking for the way to cluster a points, grouping a neighbourhood points together, but since I don't know number clusters in the data and therefore the k-mean clustering can't be use. After do some search on Google and our good friend Wikipedia I come across this alternative clustering algorithm.

DBSCAN is short from Density-Based Spatial Clustering of Application with Noise (reference from wiki : DBSCAN)

Explanation in plain english
DBSCAN requires two parameters: \varepsilon (eps) and the minimum number of points required to form a cluster (minPts). It starts with an arbitrary starting point that has not been visited. This point's \varepsilon-neighborhood is retrieved, and if it contains sufficiently many points, a cluster is started. Otherwise, the point is labeled as noise. Note that this point might later be found in a sufficiently sized \varepsilon-environment of a different point and hence be made part of a cluster.
If a point is found to be a dense part of a cluster, its \varepsilon-neighborhood is also part of that cluster. Hence, all points that are found within the \varepsilon-neighborhood are added, as is their own \varepsilon-neighborhood when they are also dense. This process continues until the density-connected cluster is completely found. Then, a new unvisited point is retrieved and processed, leading to the discovery of a further cluster or noise.

Here is a code in Python
 #! /usr/bin/python  
 from math import sqrt, pow  
   
 class DBSCAN:  
 #Density-Based Spatial Clustering of Application with Noise -> http://en.wikipedia.org/wiki/DBSCAN  
   def __init__(self):  
     self.name = 'DBSCAN'  
     self.DB = [] #Database  
     self.esp = 4 #neighborhood distance for search  
     self.MinPts = 2 #minimum number of points required to form a cluster  
     self.cluster_inx = -1  
     self.cluster = []  
       
   def DBSCAN(self):  
     for i in range(len(self.DB)):  
       p_tmp = self.DB[i]  
       if (not p_tmp.visited):  
         #for each unvisited point P in dataset  
         p_tmp.visited = True  
         NeighborPts = self.regionQuery(p_tmp)  
         if(len(NeighborPts) < self.MinPts):  
           #that point is a noise  
           p_tmp.isnoise = True  
           print p_tmp.show(), 'is a noise'  
         else:  
           self.cluster.append([])  
           self.cluster_inx = self.cluster_inx + 1  
           self.expandCluster(p_tmp, NeighborPts)     
       
   def expandCluster(self, P, neighbor_points):  
     self.cluster[self.cluster_inx].append(P)  
     iterator = iter(neighbor_points)  
     while True:  
       try:   
         npoint_tmp = iterator.next()  
       except StopIteration:  
         # StopIteration exception is raised after last element  
         break  
       if (not npoint_tmp.visited):  
         #for each point P' in NeighborPts   
         npoint_tmp.visited = True  
         NeighborPts_ = self.regionQuery(npoint_tmp)  
         if (len(NeighborPts_) >= self.MinPts):  
           for j in range(len(NeighborPts_)):  
             neighbor_points.append(NeighborPts_[j])  
       if (not self.checkMembership(npoint_tmp)):  
         #if P' is not yet member of any cluster  
         self.cluster[self.cluster_inx].append(npoint_tmp)  
       else:  
         print npoint_tmp.show(), 'is belonged to some cluster'  
   
   def checkMembership(self, P):  
     #will return True if point is belonged to some cluster  
     ismember = False  
     for i in range(len(self.cluster)):  
       for j in range(len(self.cluster[i])):  
         if (P.x == self.cluster[i][j].x and P.y == self.cluster[i][j].y):  
           ismember = True  
     return ismember  
       
   def regionQuery(self, P):  
   #return all points within P's eps-neighborhood, except itself  
     pointInRegion = []  
     for i in range(len(self.DB)):  
       p_tmp = self.DB[i]  
       if (self.dist(P, p_tmp) < self.esp and P.x != p_tmp.x and P.y != p_tmp.y):  
         pointInRegion.append(p_tmp)  
     return pointInRegion  
   
   def dist(self, p1, p2):  
   #return distance between two point  
     dx = (p1.x - p2.x)  
     dy = (p1.y - p2.y)  
     return sqrt(pow(dx,2) + pow(dy,2))  
   
 class Point:  
   def __init__(self, x = 0, y = 0, visited = False, isnoise = False):  
     self.x = x  
     self.y = y  
     self.visited = False  
     self.isnoise = False  
   
   def show(self):  
     return self.x, self.y  
       
 if __name__=='__main__':  
   #this is a mocking data just for test  
   vecPoint = [Point(11,3), Point(10,4), Point(11,5), Point(12,4), Point(13,5), Point(12,6), Point(6,10), Point(8,10), Point(5,12), Point(7,12)]  
   
   #Create object  
   dbScan = DBSCAN()  
   #Load data into object  
   dbScan.DB = vecPoint;  
   #Do clustering  
   dbScan.DBSCAN()  
   #Show result cluster  
   for i in range(len(dbScan.cluster)):  
     print 'Cluster: ', i  
     for j in range(len(dbScan.cluster[i])):  
       print dbScan.cluster[i][j].show()  


Sunday, November 25, 2012

tele-operate the Pioneer

I make some write-up about tele-operation code I have found somewhere I can't remember. May come handy later I guess.

https://sites.google.com/site/poonweb/robotics/tele-operation

I don't know how to put a code nicely on blogger, so I put it at my (long untouched) Google site.

Nice ROS installation guide

I have come across this site showing guide on ROS installation made easy, which really made it easy with step-by-step to install ROS. Should be very useful for anyone who looking for a "sure way" to install ROS on Ubuntu.

There site also have many interesting articles as well!

Tuesday, October 2, 2012

NASA Select Advanced Robotics Projects for Development


NASA ได้เลือก 8 โปรเจกต์ที่เกี่ยวข้องกับเทคโนโลยีหุ่นยนต์เพื่อที่จะนำไปใช้ในภารกิจการสำรวจอวกาศในอนาคต  โปรเจกต์ที่ได้รับการคัดเลือกมามีตั้งแต่โปรเจกต์ที่จะพัฒนาความสามารถของหุ่นยนต์สำรวจ (robotic planetary rovers) ไปจนถึงหุ่นยนต์เสมือนมนุษย์ (humanoid robotics systems)
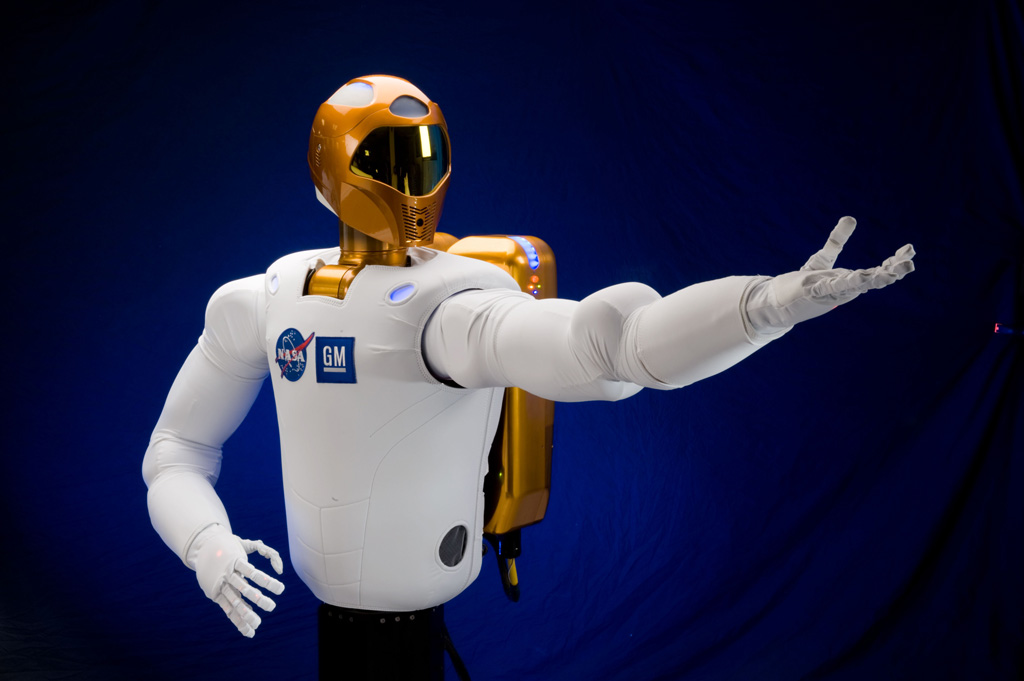
ตัวอย่างหนึ่งของหุ่นยนต์ที่ทำงานเคียงข้างและคอยช่วยเหลือมนุษย์ในอวกาศก็คือ Robonaut หุ่นยนต์คล้ายมนุษย์ที่มีร่างกายแค่ส่วนบนของ NASA เป็นหุ่นยนต์ซึ่งนับเป็นหนึ่งในสมาชิกบนสถานีอวกาศนานาชาติที่ได้รับการทดสอบการใช้งานจริง และเริ่มช่วยเหลือการทำงานของนักบินอวกาศแล้ว ทำให้นักบินอวกาศมีเวลาที่จะนำไปใช้กับงานในห้องทดลองซึ่งมีความซับซ้อนและสำคัญกว่านานขึ้น 
จุดมุ่งหมายของ NASA ที่ต้องการพัฒนาขีดความสามารถของหุ่นยนต์นั้นก็เพื่อต้องการให้หุ่นยนต์สามารถทำงานเคียงข้างกับมนุษย์ทั้งบนโลกและในอวกาศ ซึ่งจะทำให้มนุษย์ทำงานได้อย่างมีประสิทธิภาพสูงสุด ลดข้อจำกัดด้านความสามารถของมนุษย์ และปรับปรุงเรื่องความปลอดภัยในการทำงานให้มากขึ้น
รายชื่อ 8 โปรเจกต์ที่ได้รับการสนับสนุนโดย NASA มีดังต่อไปนี้

  • หุ่นยนต์อวตาร (หุ่นยนต์ที่เคลื่อนไหวตามมนุษย์ผู้ควบคุมระยะไกล),  ”Toward Human Avatar Robots for Co-Exploration of Hazardous Environments,” J. Pratt, principal investigator, Florida Institute of Human Machine Cognition, Pensacola
  • ระบบขาเทียม,  ”A Novel Powered Leg Prosthesis Simulator for Sensing and Control Development,” H. Herr, principal investigator, Massachusetts Institute of Technology, Cambridge 
  • ระบบทำนายลักษณะพื้นผิวที่มีความอันตรายต่อหุ่นยนต์สำรวจ, “Long-range Prediction of Non-Geometric Terrain Hazards for Reliable Planetary Rover Traverse,” R. Whittaker, principal investigator, Carnegie Mellon University, Pittsburgh 
  • ผิวจำลองที่มีความสามารถในการรับรู้สำหรับหุ่นยนต์,  ”Active Skins for Simplified Tactile Feedback in Robotics,” S. Bergbreiter, principal investigator, University of Maryland, College Park 
  • ระบบส่งกำลังสำหรับหุ่นยนต์เสมือนมนุษย์, “Actuators for Safe, Strong and Efficient Humanoid Robots,” S. Pekarek, principal investigator, Purdue University
  • ระบบควบคุมหุ่นยนต์ระยะไกล,  ”Whole-body Telemanipulation of the Dreamer Humanoid Robot on Rough Terrains Using Hand Exoskeleton (EXODREAM),” L. Sentis, principal investigator, University of Texas at Austin 
  • หุ่นยนต์แบบบาง ๆ ยาว ๆ, ”Long, Thin Continuum Robots for Space Applications,” I. Walker, principal investigator, Clemson University, Clemson, S.C. 
  • ระบบควบคุมสำหรับหยิบจับวัตถุอ่อนนิ่ม,  ”Manipulating Flexible Materials Using Sparse Coding,” R. Platt, principal investigator, State University of New York, Buffalo 
NASA มีประวัติอันยาวนานในการพัฒนาเทคโนโลยีล้ำสมัยสำหรับการใช้งานในอวกาศ นอกจากนี้ NASA ยังได้ร่วมมือกับภาคเอกชนภายในสหรัฐฯ มหาวิทยาลัย และภาครัฐฯ ในการถ่ายทอดเทคโนโลยีเหล่านี้กลับสู่ภาคอุตสาหกรรมของสหรัฐฯ เพื่อเพิ่มความสามารถด้านการผลิต และการแข่งขันด้านเศรษฐกิจอีกด้วย
จากข่าวนี้เราจะเห็นได้ว่า NASA ได้เน้นความสำคัญไปที่การรับรู้และการควบคุมระยะไกลนั่นเอง

อ้างอิง

NASA